공개 데이터 기준: · 사이트 반영: · 갱신 지연: 8일 이상 지난 공개본입니다.
실제 제품 사진 · 출처 aifitlab.com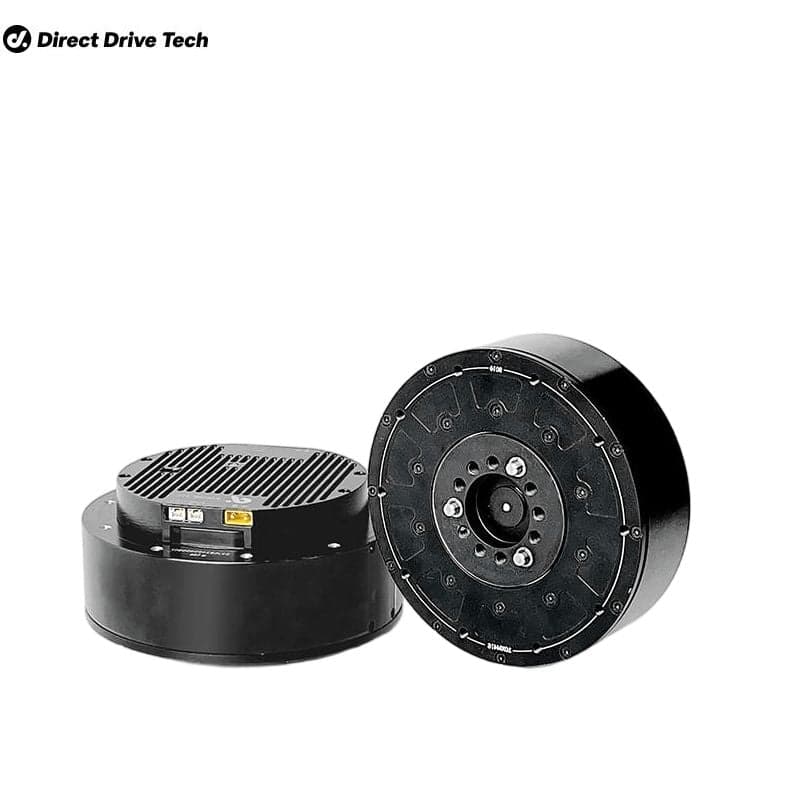 1 / 1
1 / 1사양 36근거 [n]출처 2
1
이 브라우저의 장바구니에 담깁니다 — 계정도 연락처도 필요 없습니다.
이 사이트가 가진 가격은 유통사가 표시한 값이라 바로 결제하지 않습니다 — 견적으로 실제 조건을 확인해 드립니다.
배송 · 리드타임[값]
사양.
발주 전에 확인하세요.
항목 · key값원문 문장출처근거수집 · 변경
무부하 회전수no_load_speed
값측정 조건 정격 전압 48VDC · 감속비 10:1
≥170RPM
원문 문장No-Load Speed (Current Loop) ≥170RPM
출처https://aifitlab.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-08-26변경 —
정격 회전수rated_speed
값측정 조건 정격 전압 48VDC · 감속비 10:1
원문 100±3 RPM100 r/min
원문 문장Rated Speed 100±3 RPM
출처https://aifitlab.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-08-26변경 —
정격 토크rated_torque
값측정 조건 정격 전압 48VDC · 감속비 10:1
원문 25N·m25 N·m
원문 문장Rated Torque 25N·m
출처https://aifitlab.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-08-26변경 —
정격 전류rated_current
값측정 조건 정격 전압 48VDC · 감속비 10:1
원문 6.6A±0.3A6.6 A
원문 문장Rated Current (Bus) 6.6A±0.3A
출처https://aifitlab.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-08-26변경 —
정격 전압rated_voltage
값측정 조건 감속비 10:1
원문 48VDC48 V
원문 문장Rated Voltage 48VDC
출처https://aifitlab.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-08-26변경 —
토크 상수torque_constant
값측정 조건 정격 전압 48VDC · 감속비 10:1
원문 2.5 Nm/A2.5 N·m/A
원문 문장Torque Constant 2.5 Nm/A
출처https://aifitlab.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-08-26변경 —
보호등급ip_rating
값측정 조건 정격 전압 48VDC · 감속비 10:1
IP2X
원문 문장Protection Rating (IP Rating) IP2X
출처https://aifitlab.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-08-26변경 —
소음noise_level
값측정 조건 정격 전압 48VDC · 감속비 10:1
≤65 dB (Tested per GB/T 4214.1-2017 at 150 rpm)
원문 문장Noise Level ≤65 dB (Tested per GB/T 4214.1-2017 at 150 rpm)
출처https://aifitlab.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-08-26변경 —
절연 등급insulation_class
값측정 조건 정격 전압 48VDC · 감속비 10:1
F
원문 문장Insulation Class F
출처https://aifitlab.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-08-26변경 —
무게weight
값측정 조건 정격 전압 48VDC · 감속비 10:1
원문 1.4KG1.4 kg
원문 문장Motor Weight 1.4KG
출처https://aifitlab.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-08-26변경 —
엔코더 분해능encoder_resolution
값측정 조건 정격 전압 48VDC · 감속비 10:1
15-bit (Rotor Position Detection) + 15-bit (Absolute Position Detection)
원문 문장Encoder Resolution (Bits) 15-bit (Rotor Position Detection) + 15-bit (Absolute Position Detection)
출처https://aifitlab.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-08-26변경 —
권선 저항winding_resistance
값측정 조건 정격 전압 48VDC · 감속비 10:1
원문 0.166Ω0.166 Ω
원문 문장Phase Resistance 0.166Ω
출처https://aifitlab.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-08-26변경 —
권선 인덕턴스winding_inductance
값측정 조건 정격 전압 48VDC · 감속비 10:1
원문 0.175mH0.175 mH
원문 문장Phase Inductance 0.175mH
출처https://aifitlab.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-08-26변경 —
로터 관성rotor_inertia
값측정 조건 정격 전압 48VDC · 감속비 10:1
5350g/cm^2
원문 문장Rotor Inertia 5350g/cm^2
출처https://aifitlab.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-08-26변경 —
감속비reduction_ratio
값측정 조건 정격 전압 48VDC
원문 10:110
원문 문장Reduction Ratio (Gear Ratio) 10:1
출처https://aifitlab.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-08-26변경 —
백래시backlash
값측정 조건 정격 전압 48VDC · 감속비 10:1
<8arcmin
원문 문장Backlash <8arcmin
출처https://aifitlab.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-08-26변경 —
무부하 전류no_load_current
값측정 조건 정격 전압 48VDC · 감속비 10:1
≤1.1A
원문 문장No-Load Current (Current Loop) ≤1.1A
출처https://aifitlab.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-08-26변경 —
사용 전압 범위operating_voltage_range
값측정 조건 정격 전압 48VDC · 감속비 10:1
36-60VDC (Default Under/Over-Voltage Thresholds)
원문 문장Voltage Range 36-60VDC (Default Under/Over-Voltage Thresholds)
출처https://aifitlab.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-08-26변경 —
무부하 회전수no_load_speed
값측정 조건 정격 전압 48VDC · 감속비 10:1
≥170RPM
원문 문장No-Load Speed (Current Loop) ≥170RPM
출처https://robotopian.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-09-01변경 —
무부하 전류no_load_current
값측정 조건 정격 전압 48VDC · 감속비 10:1
≤1.1A
원문 문장No-Load Current (Current Loop) ≤1.1A
출처https://robotopian.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-09-01변경 —
정격 회전수rated_speed
값측정 조건 정격 전압 48VDC · 감속비 10:1
원문 100±3 RPM100 r/min
원문 문장Rated Speed 100±3 RPM
출처https://robotopian.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-09-01변경 —
정격 토크rated_torque
값측정 조건 정격 전압 48VDC · 감속비 10:1
원문 25N·m25 N·m
원문 문장Rated Torque 25N·m
출처https://robotopian.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-09-01변경 —
정격 전류rated_current
값측정 조건 정격 전압 48VDC · 감속비 10:1
원문 6.6A±0.3A6.6 A
원문 문장Rated Current (Bus) 6.6A±0.3A
출처https://robotopian.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-09-01변경 —
정격 전압rated_voltage
값측정 조건 감속비 10:1
원문 48VDC48 V
원문 문장Rated Voltage 48VDC
출처https://robotopian.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-09-01변경 —
사용 전압 범위operating_voltage_range
값측정 조건 정격 전압 48VDC · 감속비 10:1
36-60VDC (Default Under/Over-Voltage Thresholds)
원문 문장Voltage Range 36-60VDC (Default Under/Over-Voltage Thresholds)
출처https://robotopian.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-09-01변경 —
토크 상수torque_constant
값측정 조건 정격 전압 48VDC · 감속비 10:1
원문 2.5 Nm/A2.5 N·m/A
원문 문장Torque Constant 2.5 Nm/A
출처https://robotopian.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-09-01변경 —
보호등급ip_rating
값측정 조건 정격 전압 48VDC · 감속비 10:1
IP2X
원문 문장Protection Rating (IP Rating) IP2X
출처https://robotopian.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-09-01변경 —
소음noise_level
값측정 조건 정격 전압 48VDC · 감속비 10:1
≤65 dB (Tested per GB/T 4214.1-2017 at 150 rpm)
원문 문장Noise Level ≤65 dB (Tested per GB/T 4214.1-2017 at 150 rpm)
출처https://robotopian.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-09-01변경 —
절연 등급insulation_class
값측정 조건 정격 전압 48VDC · 감속비 10:1
F
원문 문장Insulation Class F
출처https://robotopian.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-09-01변경 —
무게weight
값측정 조건 정격 전압 48VDC · 감속비 10:1
원문 1.4KG1.4 kg
원문 문장Motor Weight 1.4KG
출처https://robotopian.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-09-01변경 —
엔코더 분해능encoder_resolution
값측정 조건 정격 전압 48VDC · 감속비 10:1
15-bit (Rotor Position Detection) + 15-bit (Absolute Position Detection)
원문 문장Encoder Resolution (Bits) 15-bit (Rotor Position Detection) + 15-bit (Absolute Position Detection)
출처https://robotopian.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-09-01변경 —
권선 저항winding_resistance
값측정 조건 정격 전압 48VDC · 감속비 10:1
원문 0.166Ω0.166 Ω
원문 문장Phase Resistance 0.166Ω
출처https://robotopian.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-09-01변경 —
권선 인덕턴스winding_inductance
값측정 조건 정격 전압 48VDC · 감속비 10:1
원문 0.175mH0.175 mH
원문 문장Phase Inductance 0.175mH
출처https://robotopian.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-09-01변경 —
로터 관성rotor_inertia
값측정 조건 정격 전압 48VDC · 감속비 10:1
5350g/cm^2
원문 문장Rotor Inertia 5350g/cm^2
출처https://robotopian.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-09-01변경 —
감속비reduction_ratio
값측정 조건 정격 전압 48VDC
원문 10:110
원문 문장Reduction Ratio (Gear Ratio) 10:1
출처https://robotopian.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-09-01변경 —
백래시backlash
값측정 조건 정격 전압 48VDC · 감속비 10:1
<8arcmin
원문 문장Backlash <8arcmin
출처https://robotopian.com/products/direct-drive-tech-p1010a_111-motor · 유통사 페이지
근거출처 있음
수집 · 변경2026-09-01변경 —
사양 36중 36 표시
원문 문서.
값을 읽은 출처 2건
문서 2
다운로드원문 파일은 아직 공개하지 않습니다 — 어떤 문서를 공개할지 정해지지 않았습니다.
변경 없음
2026-08-26최초 수집 · 출처 2건
다음 업데이트2026-10-01
변경 이력 보관
JOINT · P1010A_111 · 미분류
상태대상 아님
- 부품군 미정
판정 전 확인 항목