Data captured: · Published: · Update delayed: this release is over 8 days old.
Photograph of the part · from robotopian.com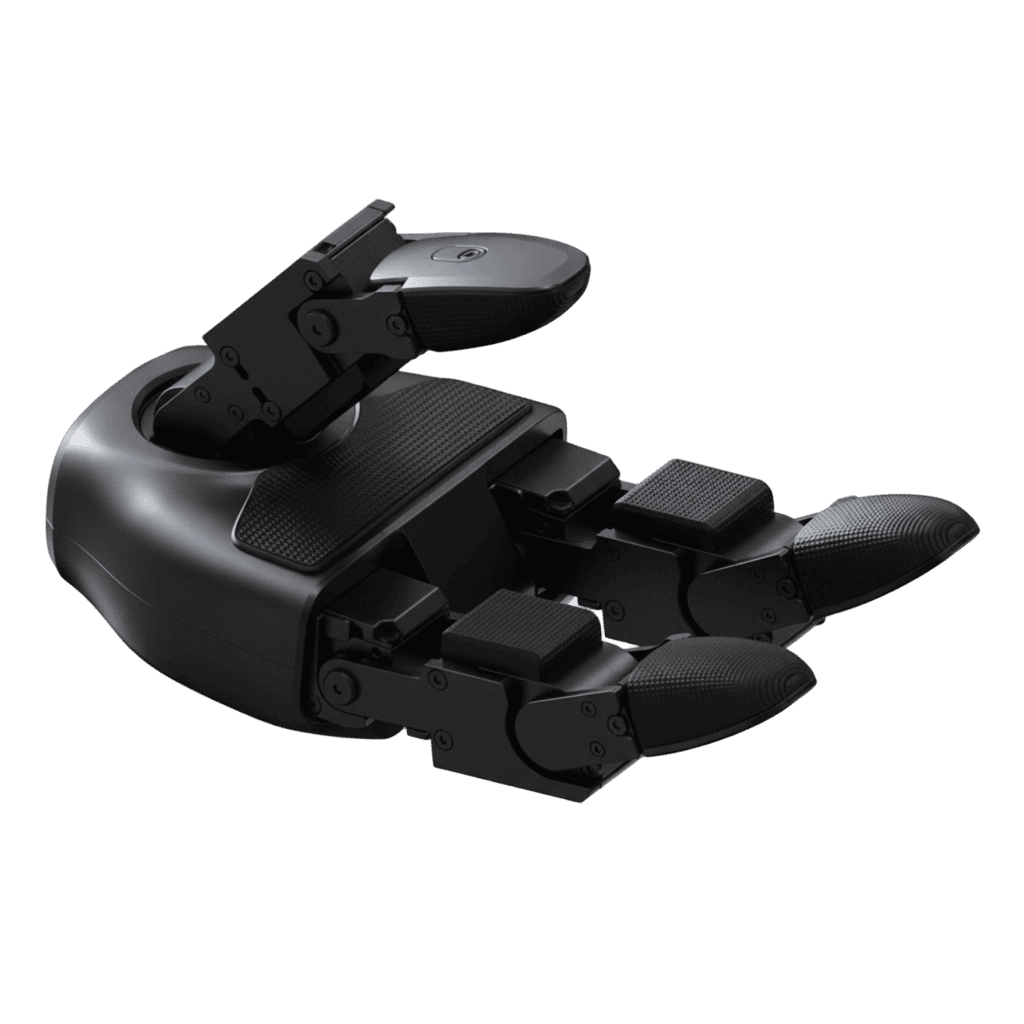 1 / 1
1 / 1specs 4evidence [n]sources 1
0.71 kgWeight
10 APeak current
1
Added to this browser's cart — no account, no contact details.
The prices here are distributors' listed figures, so this page does not take payment — a quote comes back with the real terms.
Shipping · lead time[value]
Specs.
Check before you order.
field · keyvaluesource sentencesourceEvidenceRetrieved · Changed
Weightweight
value
as printed 710g0.71 kg
source sentenceWeight 710g
sourcehttps://robotopian.com/products/unitree-dex3-1-dexterous-hand · Distributor page
EvidenceSourced
Retrieved · Changed2026-09-01Changed —
Peak currentpeak_current
value
as printed 10A10 A
source sentenceMaximum Current 10A
sourcehttps://robotopian.com/products/unitree-dex3-1-dexterous-hand · Distributor page
EvidenceSourced
Retrieved · Changed2026-09-01Changed —
Protocolprotocol
value
USB2.0
source sentenceCommunication Interface USB2.0
sourcehttps://robotopian.com/products/unitree-dex3-1-dexterous-hand · Distributor page
EvidenceSourced
Retrieved · Changed2026-09-01Changed —
Idle currentidle_current
value
58V @ 0.2A
source sentenceStatic Current 58V @ 0.2A
sourcehttps://robotopian.com/products/unitree-dex3-1-dexterous-hand · Distributor page
EvidenceSourced
Retrieved · Changed2026-09-01Changed —
specs 4, 4 shown
Source documents.
1 source the values were read from
1 documents
robotopian.com/products/unitree-dex3-1-dexterous-handDistributor page · 4 valuesRetrieved 2026-09-01
DownloadSource files are not published yet: which documents may be published is undecided.
No change
2026-09-01first collected · 1 sources
Next update2026-10-01
Change history kept
Build a joint around this part.
Put a motor, a reducer and an encoder into the slots to see whether they combine.
Check joint combinationsJOINT · Dex3-1 · N · Humanoid-specific modules
StatusNeeds checking
- Missing specs for the joint check
- No verdict: the specification keys it needs are not settled
To settle before a verdict
Supplier.
WRC 2026 Beijing exhibitors, and other suppliers.
This supplier's parts 17Supplier page
Alternatives in preparation
Keep this part in your BOM.
When the BOM opens, you can collect parts and send one enquiry.