数据采集时间: · 发布时间: · 更新延迟:公开数据已超过8天。
实物照片 · 来源 aifitlab.com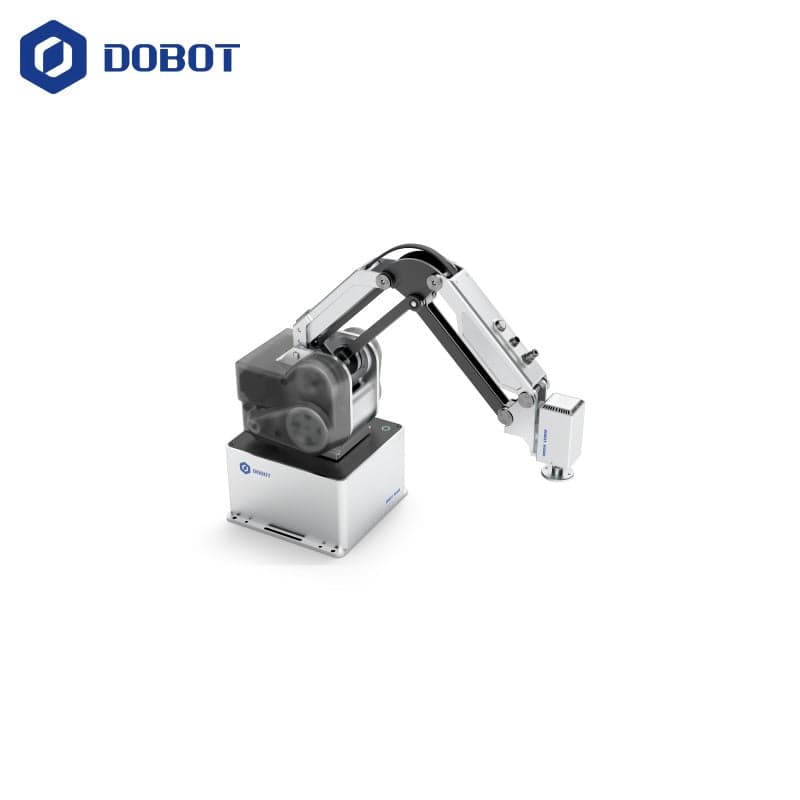 1 / 1
1 / 1非人形机器人零部件
规格 24依据 [n]来源 2
48 V额定电压
配送 · 交期[数值]
规格。
下单前请核对。
项目 · key数值原文语句来源依据采集 · 变更
额定电压rated_voltage
数值
原文 DC 48 V48 V
原文语句Rated Voltage DC 48 V
来源https://aifitlab.com/products/dobot-mg400-collaborative-robot · 经销商页面
依据有出处
采集 · 变更2026-08-26变更 —
额定功率rated_power
数值测试条件 额定电压 DC 48 V
J1:75W J2:50W J3:50W J4:30W
原文语句Rated Power J1:75W J2:50W J3:50W J4:30W
来源https://aifitlab.com/products/dobot-mg400-collaborative-robot · 经销商页面
依据有出处
采集 · 变更2026-08-26变更 —
重量weight
数值测试条件 额定电压 DC 48 V
原文 8kg8 kg
原文语句Weight 8kg
来源https://aifitlab.com/products/dobot-mg400-collaborative-robot · 经销商页面
依据有出处
采集 · 变更2026-08-26变更 —
额定电压rated_voltage
数值
原文 DC 48 V48 V
原文语句Rated Voltage DC 48 V
来源https://robotopian.com/products/dobot-mg400-collaborative-robot · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
额定功率rated_power
数值测试条件 额定电压 DC 48 V
J1:75W J2:50W J3:50W J4:30W
原文语句Rated Power J1:75W J2:50W J3:50W J4:30W
来源https://robotopian.com/products/dobot-mg400-collaborative-robot · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
重量weight
数值测试条件 额定电压 DC 48 V
原文 8kg8 kg
原文语句Weight 8kg
来源https://robotopian.com/products/dobot-mg400-collaborative-robot · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
通信方式protocol
数值测试条件 额定电压 DC 48 V
TCP/IP, Modbus TCP
原文语句Communication TCP/IP, Modbus TCP
来源https://aifitlab.com/products/dobot-mg400-collaborative-robot · 经销商页面
依据有出处
采集 · 变更2026-08-26变更 —
通信方式protocol
数值测试条件 额定电压 DC 48 V
TCP/IP, Modbus TCP
原文语句Communication TCP/IP, Modbus TCP
来源https://robotopian.com/products/dobot-mg400-collaborative-robot · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
关节运动范围joint_motion_range
数值测试条件 额定电压 DC 48 V · 关节编号 1
±160°
原文语句Joint Range J1: ±160° J2: -25°-85° J3: -25°-105° J4: -360°-360°
来源https://aifitlab.com/products/dobot-mg400-collaborative-robot · 经销商页面
依据有出处
采集 · 变更2026-08-26变更 —
关节运动范围joint_motion_range
数值测试条件 额定电压 DC 48 V · 关节编号 2
-25°-85°
原文语句Joint Range J1: ±160° J2: -25°-85° J3: -25°-105° J4: -360°-360°
来源https://aifitlab.com/products/dobot-mg400-collaborative-robot · 经销商页面
依据有出处
采集 · 变更2026-08-26变更 —
关节运动范围joint_motion_range
数值测试条件 额定电压 DC 48 V · 关节编号 3
-25°-105°
原文语句Joint Range J1: ±160° J2: -25°-85° J3: -25°-105° J4: -360°-360°
来源https://aifitlab.com/products/dobot-mg400-collaborative-robot · 经销商页面
依据有出处
采集 · 变更2026-08-26变更 —
关节运动范围joint_motion_range
数值测试条件 额定电压 DC 48 V · 关节编号 4
-360°-360°
原文语句Joint Range J1: ±160° J2: -25°-85° J3: -25°-105° J4: -360°-360°
来源https://aifitlab.com/products/dobot-mg400-collaborative-robot · 经销商页面
依据有出处
采集 · 变更2026-08-26变更 —
关节最大速度max_joint_speed
数值测试条件 额定电压 DC 48 V · 关节编号 1
原文 300°/s50 r/min
原文语句Joint Speed J1: 300°/s J2: 300°/s J3: 300°/s J4: 300°/s
来源https://aifitlab.com/products/dobot-mg400-collaborative-robot · 经销商页面
依据有出处
采集 · 变更2026-08-26变更 —
关节最大速度max_joint_speed
数值测试条件 额定电压 DC 48 V · 关节编号 2
原文 300°/s50 r/min
原文语句Joint Speed J1: 300°/s J2: 300°/s J3: 300°/s J4: 300°/s
来源https://aifitlab.com/products/dobot-mg400-collaborative-robot · 经销商页面
依据有出处
采集 · 变更2026-08-26变更 —
关节最大速度max_joint_speed
数值测试条件 额定电压 DC 48 V · 关节编号 3
原文 300°/s50 r/min
原文语句Joint Speed J1: 300°/s J2: 300°/s J3: 300°/s J4: 300°/s
来源https://aifitlab.com/products/dobot-mg400-collaborative-robot · 经销商页面
依据有出处
采集 · 变更2026-08-26变更 —
关节最大速度max_joint_speed
数值测试条件 额定电压 DC 48 V · 关节编号 4
原文 300°/s50 r/min
原文语句Joint Speed J1: 300°/s J2: 300°/s J3: 300°/s J4: 300°/s
来源https://aifitlab.com/products/dobot-mg400-collaborative-robot · 经销商页面
依据有出处
采集 · 变更2026-08-26变更 —
关节运动范围joint_motion_range
数值测试条件 额定电压 DC 48 V · 关节编号 1
±160°
原文语句Joint Range J1: ±160° J2: -25°-85° J3: -25°-105° J4: -360°-360°
来源https://robotopian.com/products/dobot-mg400-collaborative-robot · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
关节运动范围joint_motion_range
数值测试条件 额定电压 DC 48 V · 关节编号 2
-25°-85°
原文语句Joint Range J1: ±160° J2: -25°-85° J3: -25°-105° J4: -360°-360°
来源https://robotopian.com/products/dobot-mg400-collaborative-robot · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
关节运动范围joint_motion_range
数值测试条件 额定电压 DC 48 V · 关节编号 3
-25°-105°
原文语句Joint Range J1: ±160° J2: -25°-85° J3: -25°-105° J4: -360°-360°
来源https://robotopian.com/products/dobot-mg400-collaborative-robot · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
关节运动范围joint_motion_range
数值测试条件 额定电压 DC 48 V · 关节编号 4
-360°-360°
原文语句Joint Range J1: ±160° J2: -25°-85° J3: -25°-105° J4: -360°-360°
来源https://robotopian.com/products/dobot-mg400-collaborative-robot · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
关节最大速度max_joint_speed
数值测试条件 额定电压 DC 48 V · 关节编号 1
原文 300°/s50 r/min
原文语句Joint Speed J1: 300°/s J2: 300°/s J3: 300°/s J4: 300°/s
来源https://robotopian.com/products/dobot-mg400-collaborative-robot · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
关节最大速度max_joint_speed
数值测试条件 额定电压 DC 48 V · 关节编号 2
原文 300°/s50 r/min
原文语句Joint Speed J1: 300°/s J2: 300°/s J3: 300°/s J4: 300°/s
来源https://robotopian.com/products/dobot-mg400-collaborative-robot · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
关节最大速度max_joint_speed
数值测试条件 额定电压 DC 48 V · 关节编号 3
原文 300°/s50 r/min
原文语句Joint Speed J1: 300°/s J2: 300°/s J3: 300°/s J4: 300°/s
来源https://robotopian.com/products/dobot-mg400-collaborative-robot · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
关节最大速度max_joint_speed
数值测试条件 额定电压 DC 48 V · 关节编号 4
原文 300°/s50 r/min
原文语句Joint Speed J1: 300°/s J2: 300°/s J3: 300°/s J4: 300°/s
来源https://robotopian.com/products/dobot-mg400-collaborative-robot · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
规格 24 中显示 24
原文文档。
读取数值的来源 2 个
文档 2
下载原始文件尚未公开 —— 哪些文档可以公开尚未决定。
无变更
2026-08-26首次采集 · 来源 2 条
下次更新2026-10-01
保留变更记录
JOINT · DT-MG400-4R075-01 · 范围外
状态不适用
- 非人形机器人零部件
判定前需确认的事项