数据采集时间: · 发布时间: · 更新延迟:公开数据已超过8天。
实物照片 · 来源 aifitlab.com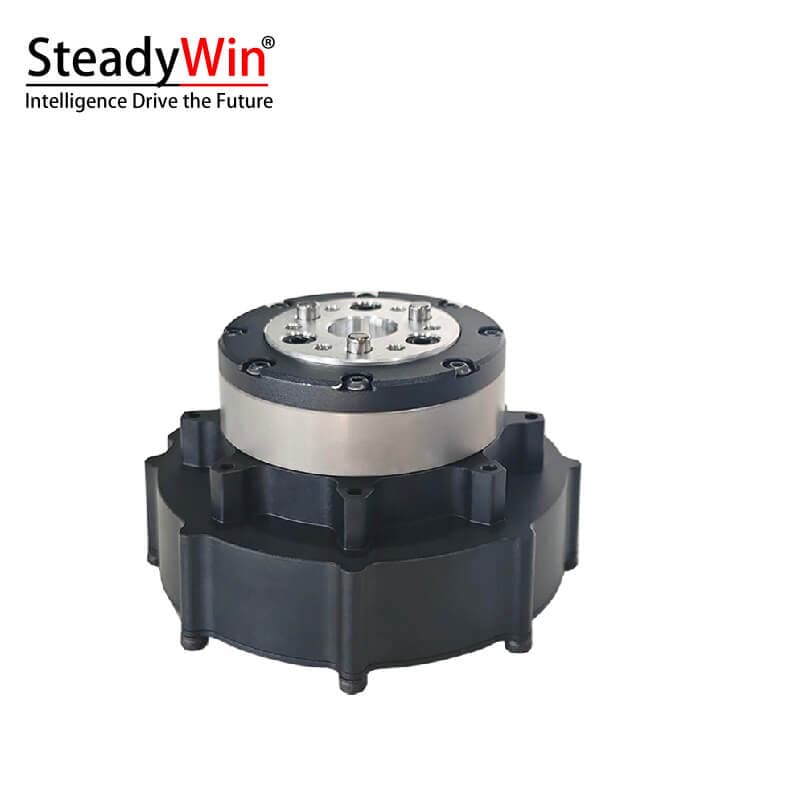 1 / 2
1 / 2照片 2 张
规格 67依据 [n]来源 2
配送 · 交期[数值]
规格。
下单前请核对。
项目 · key数值原文语句来源依据采集 · 变更
标称电压nominal_voltage
数值测试条件 驱动器型号 SDC104 · 减速比 48:1
原文 48 V (24-56V range)48 V
原文语句Nominal Voltage 48 V (24-56V range) 36V (24-40V range)
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
标称电压nominal_voltage
数值测试条件 驱动器型号 SDC215 · 减速比 48:1
原文 36V (24-40V range)36 V
原文语句Nominal Voltage 48 V (24-56V range) 36V (24-40V range)
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
额定扭矩rated_torque
数值测试条件 驱动器型号 SDC104 · 减速比 48:1
原文 45 N.M45 N·m
原文语句Nominal Torque 45 N.M 45N.M
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
额定扭矩rated_torque
数值测试条件 驱动器型号 SDC215 · 减速比 48:1
原文 45N.M45 N·m
原文语句Nominal Torque 45 N.M 45N.M
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
堵转扭矩stall_torque
数值测试条件 驱动器型号 SDC104 · 减速比 48:1
原文 132 N.M132 N·m
原文语句Stall Torque 132 N.M 131.6 N.M
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
堵转扭矩stall_torque
数值测试条件 驱动器型号 SDC215 · 减速比 48:1
原文 131.6 N.M131.6 N·m
原文语句Stall Torque 132 N.M 131.6 N.M
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
额定电流rated_current
数值测试条件 驱动器型号 SDC104 · 减速比 48:1
原文 7 A7 A
原文语句Nominal Current 7 A 5.3A
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
额定电流rated_current
数值测试条件 驱动器型号 SDC215 · 减速比 48:1
原文 5.3A5.3 A
原文语句Nominal Current 7 A 5.3A
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
堵转电流stall_current
数值测试条件 驱动器型号 SDC104 · 减速比 48:1
原文 22 A22 A
原文语句Stall Current 22 A 20.9A
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
堵转电流stall_current
数值测试条件 驱动器型号 SDC215 · 减速比 48:1
原文 20.9A20.9 A
原文语句Stall Current 22 A 20.9A
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
绕组电阻winding_resistance
数值测试条件 驱动器型号 SDC104 / SDC215 · 减速比 48:1
原文 0.67Ω0.67 Ω
原文语句Phase Resistance 0.67Ω 0.67Ω
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
绕组电感winding_inductance
数值测试条件 驱动器型号 SDC104 / SDC215 · 减速比 48:1
原文 0.45mH0.45 mH
原文语句Phase Inductance 0.45mH 0.45mH
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
扭矩常数torque_constant
数值测试条件 驱动器型号 SDC104 · 减速比 48:1
原文 6N.M/A6 N·m/A
原文语句Torque Constant 6N.M/A 8.14N.M/A
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
扭矩常数torque_constant
数值测试条件 驱动器型号 SDC215 · 减速比 48:1
原文 8.14N.M/A8.14 N·m/A
原文语句Torque Constant 6N.M/A 8.14N.M/A
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
极对数pole_pairs
数值测试条件 驱动器型号 SDC104 · 减速比 48:1
原文 21 Pairs21 pairs
原文语句Number of Pole Pairs 21 Pairs 21Pairs
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
极对数pole_pairs
数值测试条件 驱动器型号 SDC215 · 减速比 48:1
原文 21Pairs21 pairs
原文语句Number of Pole Pairs 21 Pairs 21Pairs
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
减速比reduction_ratio
数值测试条件 驱动器型号 SDC104 / SDC215
原文 48:148
原文语句Gear Ratio 48:1 48:1
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
回差backlash
数值测试条件 驱动器型号 SDC104 / SDC215 · 减速比 48:1
原文 15arcmin15 arcmin
原文语句Reducer Gear Backlash 15arcmin 15arcmin
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
重量weight
数值测试条件 驱动器型号 SDC104 · 有无驱动器 without Driver · 减速比 48:1
原文 762 g0.762 kg
原文语句Motor Weight (without Driver) 762 g 762g
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
重量weight
数值测试条件 驱动器型号 SDC215 · 有无驱动器 without Driver · 减速比 48:1
原文 762g0.762 kg
原文语句Motor Weight (without Driver) 762 g 762g
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
重量weight
数值测试条件 驱动器型号 SDC104 · 有无驱动器 with Driver · 减速比 48:1
原文 780 g0.78 kg
原文语句Motor Weight (with Driver) 780 g 780g
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
重量weight
数值测试条件 驱动器型号 SDC215 · 有无驱动器 with Driver · 减速比 48:1
原文 780g0.78 kg
原文语句Motor Weight (with Driver) 780 g 780g
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
轴向负载axial_load
数值测试条件 驱动器型号 SDC104 · 减速比 48:1
原文 225 N225 N
原文语句Max Axial Load 225 N 225N
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
轴向负载axial_load
数值测试条件 驱动器型号 SDC215 · 减速比 48:1
原文 225N225 N
原文语句Max Axial Load 225 N 225N
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
径向负载radial_load
数值测试条件 驱动器型号 SDC104 / SDC215 · 减速比 48:1
原文 900N900 N
原文语句Max Radial Load 900N 900N
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
噪声noise_level
数值测试条件 驱动器型号 SDC104 / SDC215 · 减速比 48:1
<60 dB
原文语句Noise <60 dB <60 dB
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
环境温度ambient_temperature
数值测试条件 驱动器型号 SDC104 / SDC215 · 减速比 48:1
-20℃ to +80℃
原文语句Operating Temperature -20℃ to +80℃ -20℃ to +80℃
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
编码器分辨率encoder_resolution
数值测试条件 驱动器型号 SDC104 / SDC215 · 减速比 48:1
原文 14Bit14 bit
原文语句Encoder Resolution 14Bit 14Bit
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
标称电压nominal_voltage
数值测试条件 驱动器型号 SDC104 · 减速比 48:1
原文 48V (24-56V range)48 V
原文语句Nominal Voltage 48V (24-56V range) 36V (24-40V range)
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
标称电压nominal_voltage
数值测试条件 驱动器型号 SDC215 · 减速比 48:1
原文 36V (24-40V range)36 V
原文语句Nominal Voltage 48V (24-56V range) 36V (24-40V range)
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
额定扭矩rated_torque
数值测试条件 驱动器型号 SDC104 / SDC215 · 减速比 48:1
原文 45N.M45 N·m
原文语句Nominal Torque 45N.M 45N.M
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
堵转扭矩stall_torque
数值测试条件 驱动器型号 SDC104 · 减速比 48:1
原文 132N.M132 N·m
原文语句Stall Torque 132N.M 131.6N.M
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
堵转扭矩stall_torque
数值测试条件 驱动器型号 SDC215 · 减速比 48:1
原文 131.6N.M131.6 N·m
原文语句Stall Torque 132N.M 131.6N.M
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
额定电流rated_current
数值测试条件 驱动器型号 SDC104 · 减速比 48:1
原文 7A7 A
原文语句Nominal Current 7A 5.3A
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
额定电流rated_current
数值测试条件 驱动器型号 SDC215 · 减速比 48:1
原文 5.3A5.3 A
原文语句Nominal Current 7A 5.3A
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
堵转电流stall_current
数值测试条件 驱动器型号 SDC104 · 减速比 48:1
原文 22A22 A
原文语句Stall Current 22A 20.9A
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
堵转电流stall_current
数值测试条件 驱动器型号 SDC215 · 减速比 48:1
原文 20.9A20.9 A
原文语句Stall Current 22A 20.9A
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
绕组电阻winding_resistance
数值测试条件 驱动器型号 SDC104 / SDC215 · 减速比 48:1
原文 0.67Ω0.67 Ω
原文语句Phase Resistance 0.67Ω 0.67Ω
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
绕组电感winding_inductance
数值测试条件 驱动器型号 SDC104 / SDC215 · 减速比 48:1
原文 0.45mH0.45 mH
原文语句Phase Inductance 0.45mH 0.45mH
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
扭矩常数torque_constant
数值测试条件 驱动器型号 SDC104 · 减速比 48:1
原文 6N.M/A6 N·m/A
原文语句Torque Constant 6N.M/A 8.14N.M/A
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
扭矩常数torque_constant
数值测试条件 驱动器型号 SDC215 · 减速比 48:1
原文 8.14N.M/A8.14 N·m/A
原文语句Torque Constant 6N.M/A 8.14N.M/A
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
极对数pole_pairs
数值测试条件 驱动器型号 SDC104 / SDC215 · 减速比 48:1
原文 21Pairs21 pairs
原文语句Number of Pole Pairs 21Pairs 21Pairs
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
减速比reduction_ratio
数值测试条件 驱动器型号 SDC104 / SDC215
原文 48:148
原文语句Gear Ratio 48:1 48:1
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
回差backlash
数值测试条件 驱动器型号 SDC104 / SDC215 · 减速比 48:1
原文 15arcmin15 arcmin
原文语句Reducer Gear Backlash 15arcmin 15arcmin
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
重量weight
数值测试条件 驱动器型号 SDC104 / SDC215 · 有无驱动器 without Driver · 减速比 48:1
原文 762g0.762 kg
原文语句Motor Weight (without Driver) 762g 762g
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
重量weight
数值测试条件 驱动器型号 SDC104 / SDC215 · 有无驱动器 with Driver · 减速比 48:1
原文 780g0.78 kg
原文语句Motor Weight (with Driver) 780g 780g
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
轴向负载axial_load
数值测试条件 驱动器型号 SDC104 / SDC215 · 减速比 48:1
原文 225N225 N
原文语句Max Axial Load 225N 225N
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
径向负载radial_load
数值测试条件 驱动器型号 SDC104 / SDC215 · 减速比 48:1
原文 900N900 N
原文语句Max Radial Load 900N 900N
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
噪声noise_level
数值测试条件 驱动器型号 SDC104 / SDC215 · 减速比 48:1
<60dB
原文语句Noise <60dB <60dB
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
环境温度ambient_temperature
数值测试条件 驱动器型号 SDC104 / SDC215 · 减速比 48:1
-20℃ to +80℃
原文语句Operating Temperature -20℃ to +80℃ -20℃ to +80℃
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
编码器分辨率encoder_resolution
数值测试条件 驱动器型号 SDC104 / SDC215 · 减速比 48:1
原文 14Bit14 bit
原文语句Encoder Resolution 14Bit 14Bit
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
速度常数speed_constant
数值测试条件 驱动器型号 SDC104 · 减速比 48:1
原文 1.1rpm/v1.1 rpm/V
原文语句Speed Constant 1.1rpm/v 1.11rpm/v
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
速度常数speed_constant
数值测试条件 驱动器型号 SDC215 · 减速比 48:1
原文 1.11rpm/v1.11 rpm/V
原文语句Speed Constant 1.1rpm/v 1.11rpm/v
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
通信方式protocol
数值测试条件 驱动器型号 SDC104 / SDC215 · 减速比 48:1
CAN & Type-C
原文语句Communication CAN & Type-C CAN & Type-C
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
防护等级ip_rating
数值测试条件 驱动器型号 SDC104 / SDC215 · 减速比 48:1
IP54
原文语句Protection Grade IP54 IP54
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
速度常数speed_constant
数值测试条件 驱动器型号 SDC104 · 减速比 48:1
原文 1.1rpm/v1.1 rpm/V
原文语句Speed Constant 1.1rpm/v 1.11rpm/v
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
速度常数speed_constant
数值测试条件 驱动器型号 SDC215 · 减速比 48:1
原文 1.11rpm/v1.11 rpm/V
原文语句Speed Constant 1.1rpm/v 1.11rpm/v
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
通信方式protocol
数值测试条件 驱动器型号 SDC104 / SDC215 · 减速比 48:1
CAN & Type-C
原文语句Communication CAN & Type-C CAN & Type-C
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
防护等级ip_rating
数值测试条件 驱动器型号 SDC104 / SDC215 · 减速比 48:1
IP54
原文语句Protection Grade IP54 IP54
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
额定转速rated_speed
数值测试条件 驱动器型号 SDC104 · 减速比 48:1
原文 18 RPM18 r/min
原文语句Nominal Speed after Reduction 18 RPM 32RPM
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
额定转速rated_speed
数值测试条件 驱动器型号 SDC215 · 减速比 48:1
原文 32RPM32 r/min
原文语句Nominal Speed after Reduction 18 RPM 32RPM
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
尺寸(不含驱动器)dimensions_without_driver
数值测试条件 驱动器型号 SDC104 / SDC215 · 减速比 48:1
Ø92*62mm
原文语句Size (without Driver) Ø92*62mm Ø92*62mm
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
尺寸(含驱动器)dimensions_with_driver
数值测试条件 驱动器型号 SDC104 / SDC215 · 减速比 48:1
Ø92*73mm
原文语句Size (with Driver) Ø92*73mm Ø92*73mm
来源https://aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-08-28变更 —
额定转速rated_speed
数值测试条件 驱动器型号 SDC104 · 减速比 48:1
原文 18RPM18 r/min
原文语句Nominal Speed after Reduction 18RPM 32RPM
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
额定转速rated_speed
数值测试条件 驱动器型号 SDC215 · 减速比 48:1
原文 32RPM32 r/min
原文语句Nominal Speed after Reduction 18RPM 32RPM
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
尺寸(不含驱动器)dimensions_without_driver
数值测试条件 驱动器型号 SDC104 / SDC215 · 减速比 48:1
Ø92*62mm
原文语句Size (without Driver) Ø92*62mm Ø92*62mm
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
尺寸(含驱动器)dimensions_with_driver
数值测试条件 驱动器型号 SDC104 / SDC215 · 减速比 48:1
Ø92*73mm
原文语句Size (with Driver) Ø92*73mm Ø92*73mm
来源https://robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
规格 67 中显示 67
原文文档。
读取数值的来源 2 个
文档 2
aifitlab.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor经销商页面 · 36 个数值Retrieved 2026-08-28
robotopian.com/products/steadywin-gim8108-48-planetary-reducer-servo-motor经销商页面 · 31 个数值Retrieved 2026-09-01
下载原始文件尚未公开 —— 哪些文档可以公开尚未决定。
无变更
2026-08-28首次采集 · 来源 2 条
下次更新2026-10-01
保留变更记录
JOINT · GIM8108-48 · C · Reducers
状态待确认
- 缺少关节比对所需规格
- 无判定 —— 所需规格键尚未确定
判定前需确认的事项