数据采集时间: · 发布时间: · 更新延迟:公开数据已超过8天。
实物照片 · 来源 aifitlab.com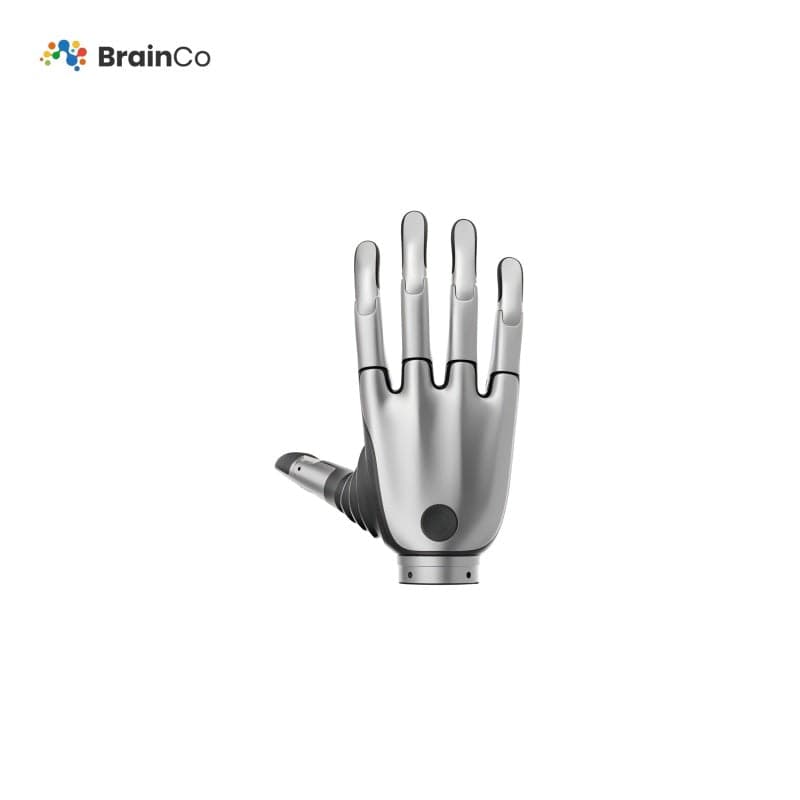 1 / 2
1 / 2照片 2 张
规格 12依据 [n]来源 4
配送 · 交期[数值]
规格。
下单前请核对。
项目 · key数值原文语句来源依据采集 · 变更
采样率sampling_rate
数值
≥50Hz
原文语句Sampling Frequency / ≥50Hz
来源https://aifitlab.com/products/brainco-bionic-dexterous-hand-revo-1 · 经销商页面
依据有出处
采集 · 变更2026-08-26变更 —
高度height
数值测试条件 额定电压 12-64V
原文 160 mm160 mm
原文语句Height (from the base of the palm to the tip of the middle finger) 160 mm 160 mm 160 mm
来源https://aifitlab.com/products/brainco-bionic-dexterous-hand-revo-2 · 经销商页面
依据有出处
采集 · 变更2026-08-26变更 —
通信方式protocol
数值测试条件 额定电压 12-64V
485 CANfd EtherCAT
原文语句Communication interface 485 CANfd 485 CANfd EtherCAT 485 CANfd EtherCAT
来源https://aifitlab.com/products/brainco-bionic-dexterous-hand-revo-2 · 经销商页面
依据有出处
采集 · 变更2026-08-26变更 —
额定电压rated_voltage
数值
12-64V
原文语句Supply voltage 12-28V 12-64V 12-64V
来源https://aifitlab.com/products/brainco-bionic-dexterous-hand-revo-2 · 经销商页面
依据有出处
采集 · 变更2026-08-26变更 —
环境温度ambient_temperature
数值测试条件 额定电压 12-64V
-10 - 40℃ / 90%RH
原文语句Operating temperature -10 - 40℃ / 90%RH -10 - 40℃ / 90%RH -10 - 40℃ / 90%RH
来源https://aifitlab.com/products/brainco-bionic-dexterous-hand-revo-2 · 经销商页面
依据有出处
采集 · 变更2026-08-26变更 —
采样率sampling_rate
数值
≥50Hz
原文语句Sampling Frequency / ≥50Hz
来源https://robotopian.com/products/brainco-bionic-dexterous-hand-revo-1 · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
高度height
数值测试条件 额定电压 12-64V
原文 160 mm160 mm
原文语句Height (from the base of the palm to the tip of the middle finger) 160 mm 160 mm 160 mm
来源https://robotopian.com/products/brainco-bionic-dexterous-hand-revo-2 · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
通信方式protocol
数值测试条件 额定电压 12-64V
485
CANfd
EtherCAT
原文语句485
CANfd
EtherCAT
来源https://robotopian.com/products/brainco-bionic-dexterous-hand-revo-2 · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
额定电压rated_voltage
数值
12-64V
原文语句Supply voltage 12-28V 12-64V 12-64V
来源https://robotopian.com/products/brainco-bionic-dexterous-hand-revo-2 · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
环境温度ambient_temperature
数值测试条件 额定电压 12-64V
-10 - 40℃ / 90%RH
原文语句Operating temperature -10 - 40℃ / 90%RH -10 - 40℃ / 90%RH -10 - 40℃ / 90%RH
来源https://robotopian.com/products/brainco-bionic-dexterous-hand-revo-2 · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
待机电流idle_current
数值测试条件 额定电压 24V
原文 115 mA @24V0.115 A
原文语句Static Current 65 mA @24V 115 mA @24V 115 mA @24V
来源https://aifitlab.com/products/brainco-bionic-dexterous-hand-revo-2 · 经销商页面
依据有出处
采集 · 变更2026-08-26变更 —
待机电流idle_current
数值测试条件 额定电压 24V
原文 115 mA @24V0.115 A
原文语句Static Current 65 mA @24V 115 mA @24V 115 mA @24V
来源https://robotopian.com/products/brainco-bionic-dexterous-hand-revo-2 · 经销商页面
依据有出处
采集 · 变更2026-09-01变更 —
规格 12 中显示 12
原文文档。
读取数值的来源 4 个
文档 4
下载原始文件尚未公开 —— 哪些文档可以公开尚未决定。
无变更
2026-08-26首次采集 · 来源 4 条
下次更新2026-10-01
保留变更记录
JOINT · TOUCH · N · Humanoid-specific modules
状态待确认
- 缺少关节比对所需规格
- 无判定 —— 所需规格键尚未确定
判定前需确认的事项